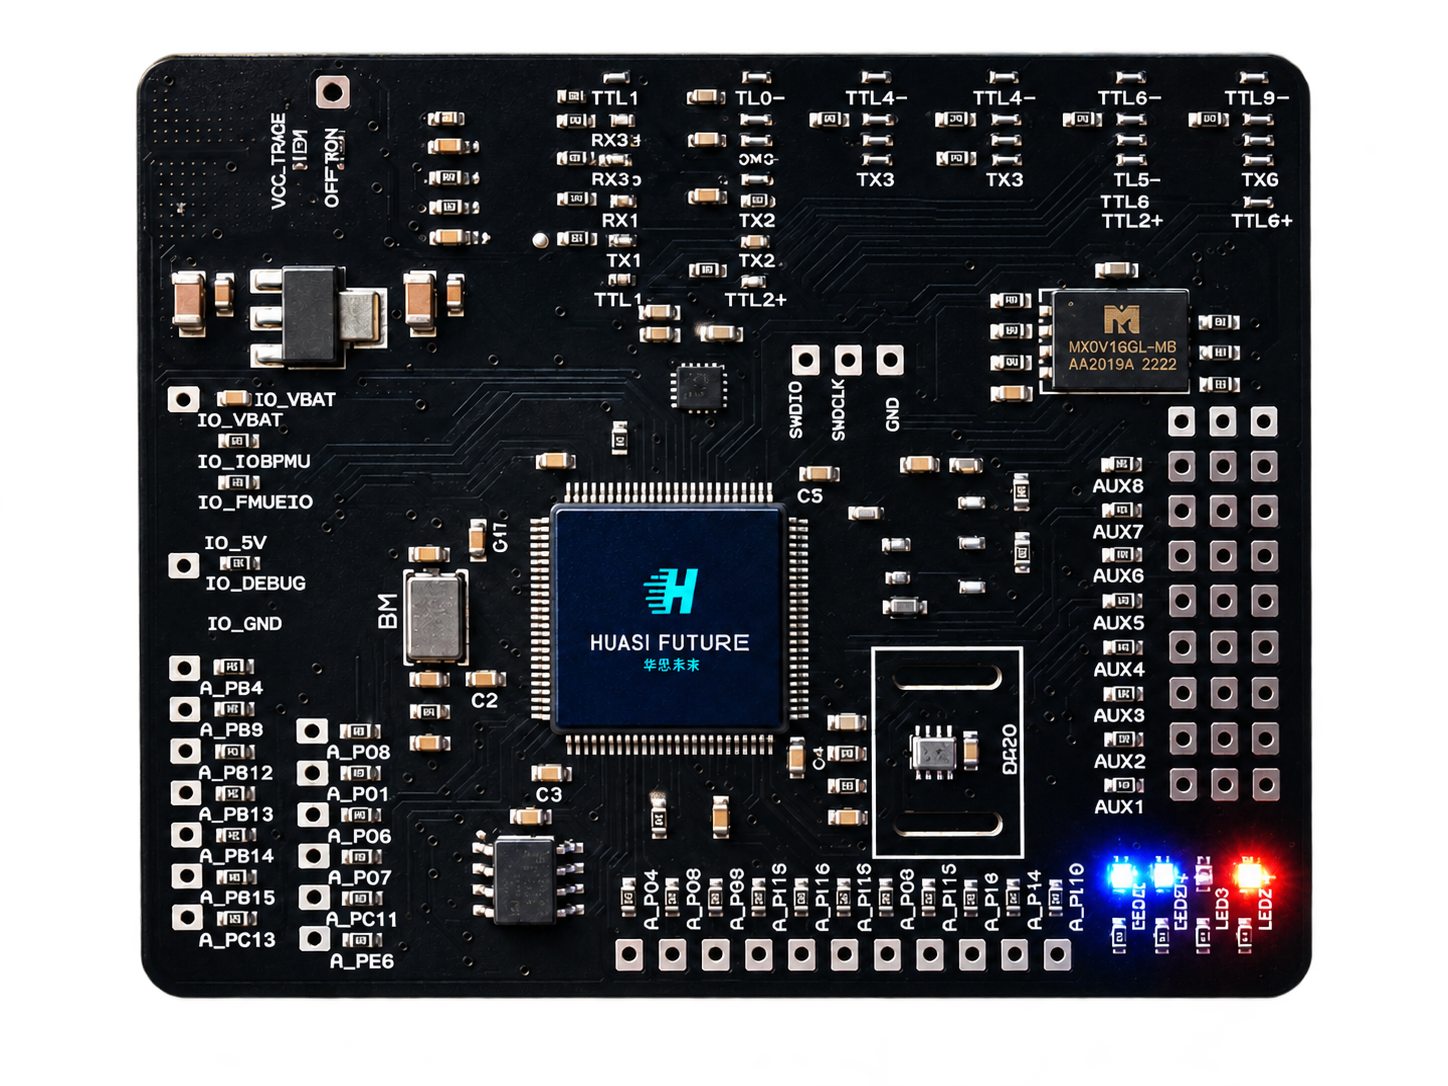
H743 高性能自动驾驶仪H743 High-Performance Autopilot
PX4H743Pilot
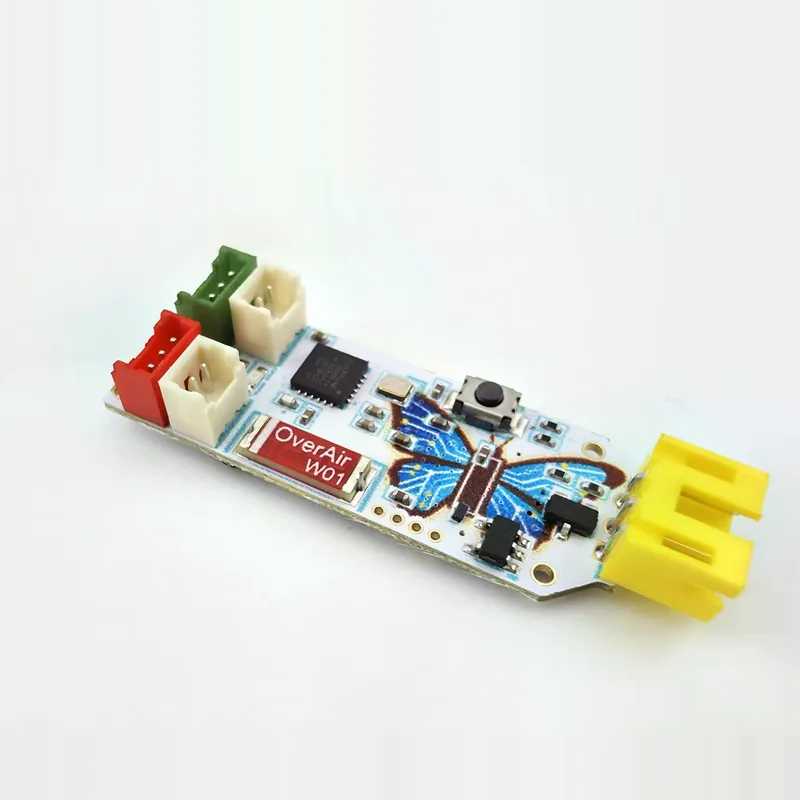
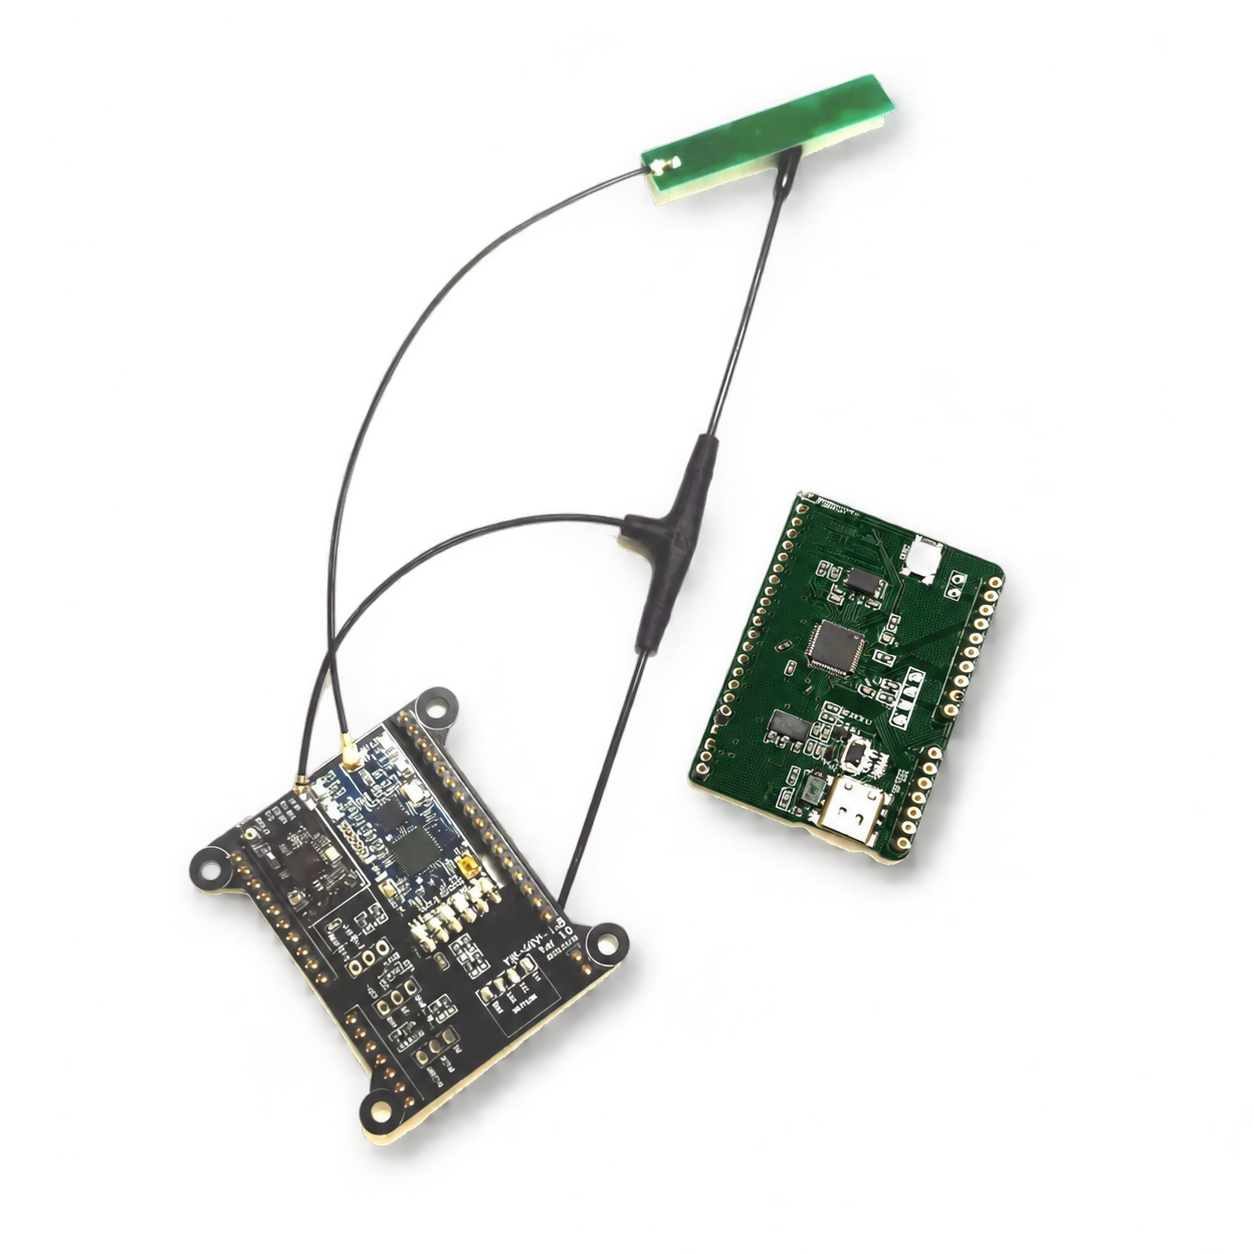
PX4H743Pilot 是一款基于 STM32H7 微控制器的开源自动驾驶仪板。它使用 EKF2 扩展卡尔曼滤波进行状态估计,面向对姿态解算速度和控制响应有较高要求的飞行平台。PX4H743Pilot is an open-source autopilot board based on an STM32H7 microcontroller. It uses the EKF2 extended Kalman filter for state estimation and is designed for aircraft that require fast attitude estimation and responsive flight control.
- 主控平台Controller platform
- STM32H7
- 状态估计State estimation
- EKF2
- 飞控固件Flight control firmware
- PX4
核心特点与应用场景Key features and applications
- 实时姿态解算Real-time attitude estimation
- STM32H7 的浮点运算能力用于处理 EKF2 状态估计,支持振动环境下的姿态解算。The STM32H7 runs EKF2 state estimation to support attitude estimation under vibration.
- 科研与教学Research and education
- 可使用 PX4 v1.12.3 作为算法验证环境,进行飞控算法开发与教学实验。PX4 v1.12.3 can serve as a test environment for flight control algorithm development and teaching labs.
- 无人机平台集成UAV platform integration
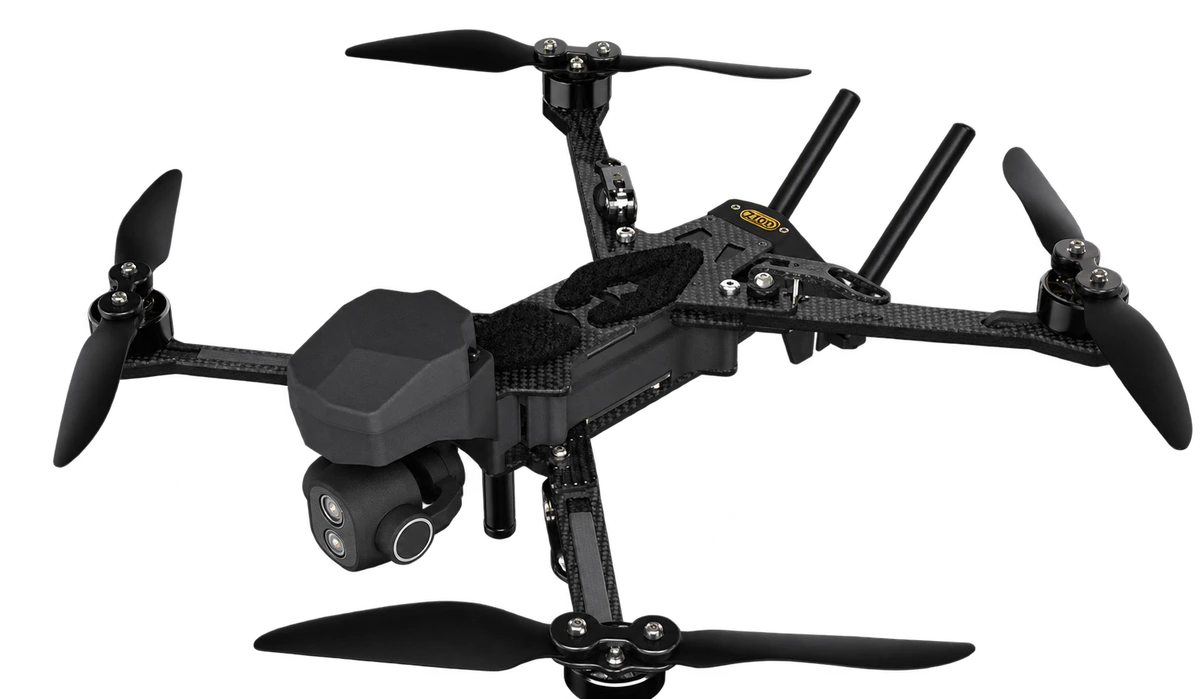
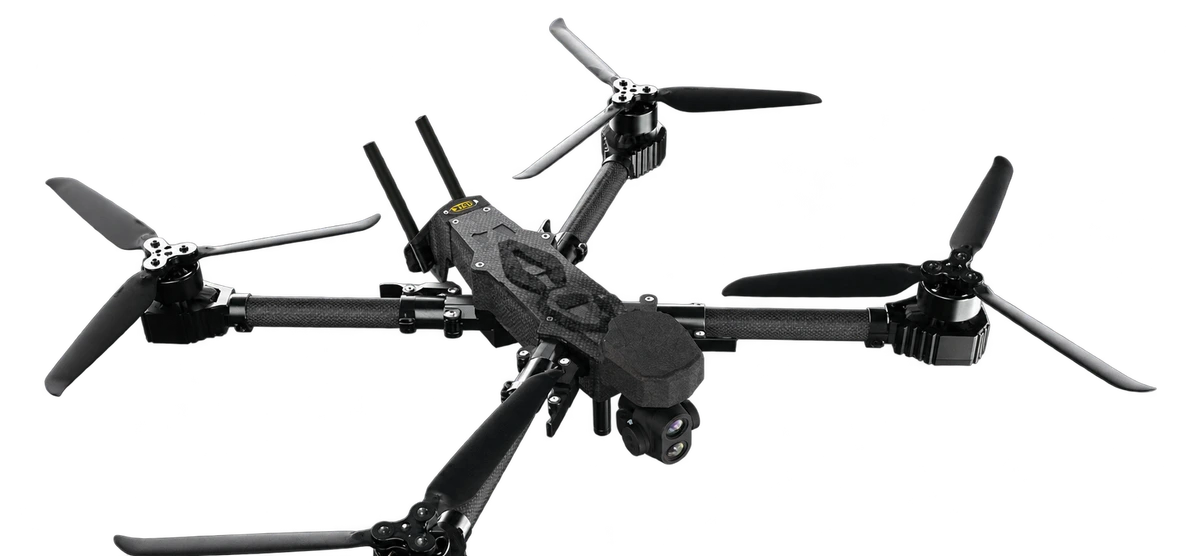
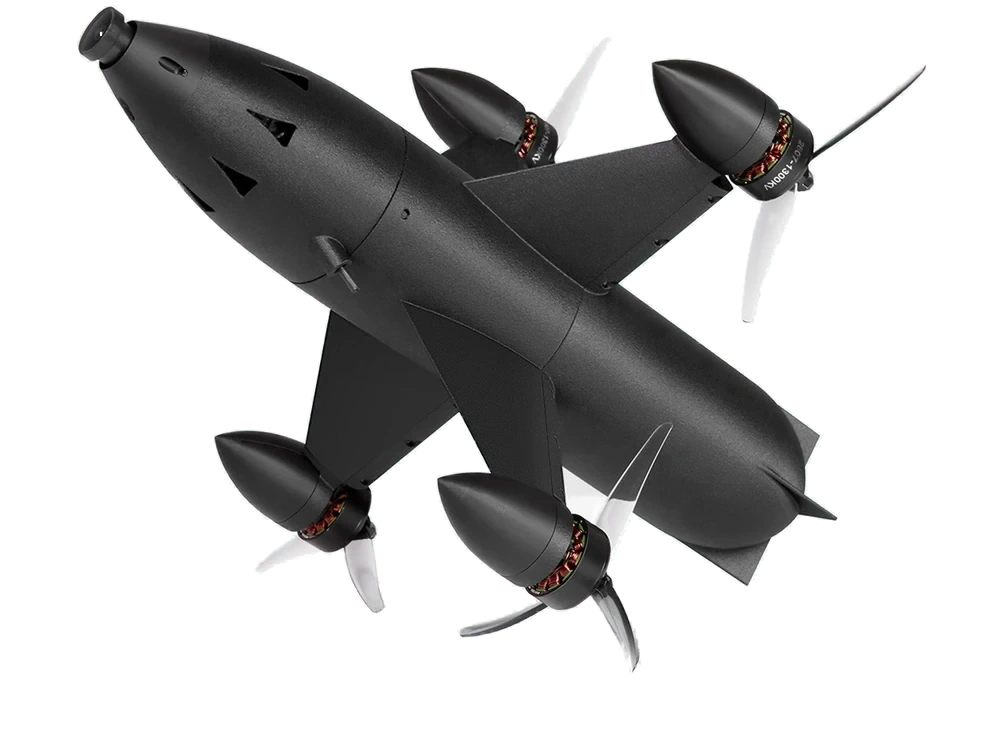
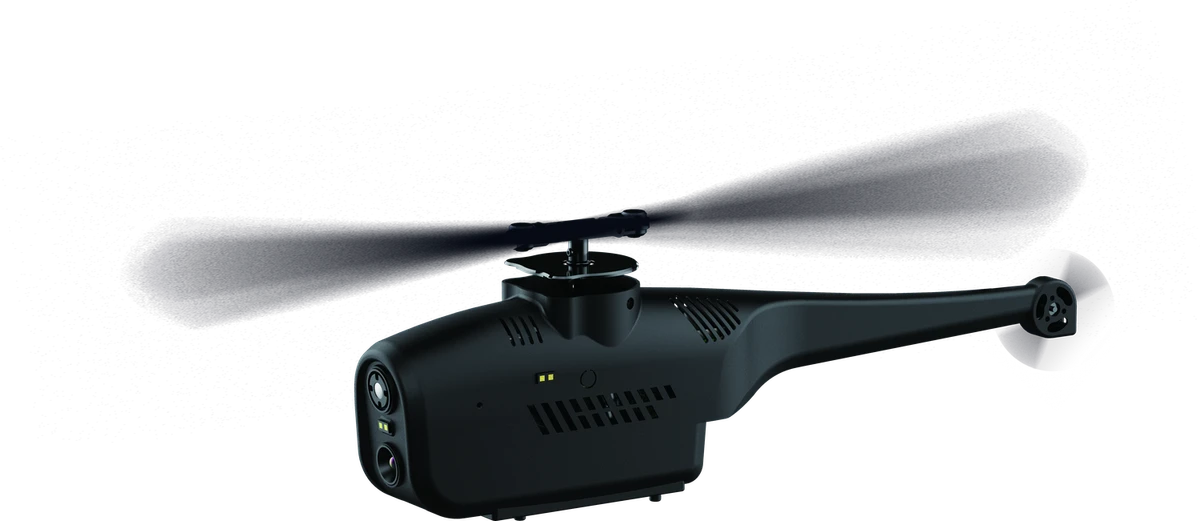
- 面向穿越机、垂直起降固定翼以及重载植保与物流无人机的飞控集成。产品资料以 500 kg 级工业无人机为应用示例。For flight control integration into FPV aircraft, fixed-wing VTOL platforms, and heavy-lift agricultural and logistics UAVs. The product documentation cites a 500 kg-class industrial UAV as an application example.
- 先进空中交通原型验证Advanced air mobility prototyping
- 面向轻型载人飞行器和 eVTOL 的原型开发与测试,飞控适配需结合整机验证。For prototype development and testing on light crewed aircraft and eVTOL platforms. Validate flight controller integration at the aircraft level.
技术与固件配置Hardware and firmware configuration
固件版本按产品资料列出。集成时请按目标机型验证固件构建与飞控配置。Firmware versions are listed in the product documentation. Verify the firmware build and flight control configuration on the intended aircraft during integration.
- 主控平台Controller platform
- STM32H7
- 状态估计算法State estimation algorithm
- EKF2 扩展卡尔曼滤波EKF2 extended Kalman filter
- 飞控固件Flight control firmware
- PX4-Autopilot
- 资料所列固件版本Documented firmware versions
- v1.12.3、v1.15.3v1.12.3 and v1.15.3
- 开发主干Development main branch
- 按具体构建验证Validate the specific build